Robotics With AI.
The era of artificial intelligence trapped behind glass is over. Meet ALLY D-1™: an autonomous 6-axis articulated desktop robot powered by an on-device Vision-Language-Action (VLA) neural engine. Real-time ±0.008 mm closed-loop precision, sub-Newton tactile force sensing, and air-gapped sovereign intelligence designed for advanced benchtop engineering.
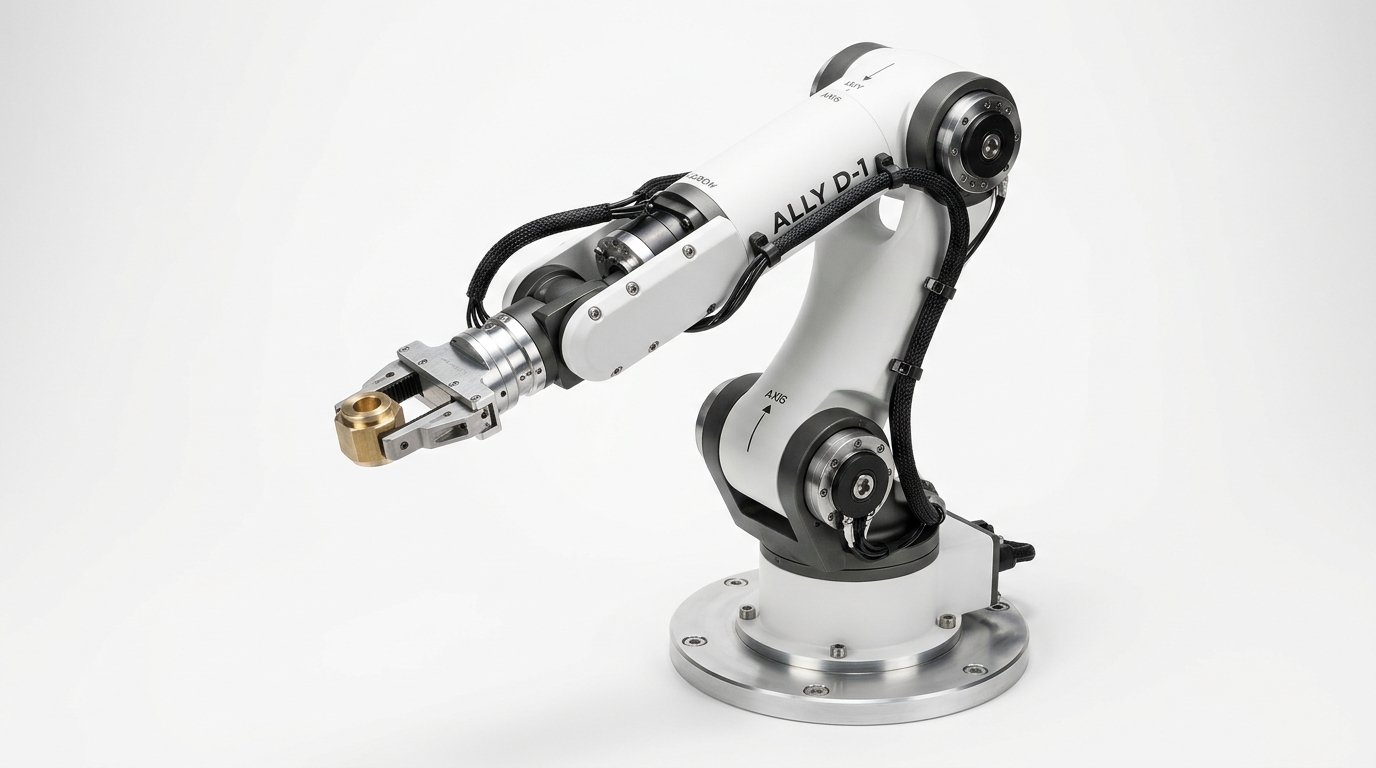
AgentOS™ V4. Zero cloud latency & air-gapped execution.
Harmonic gearing with sub-Newton tactile force feedback.
From Multimodal Perception to Autonomous Action.
Traditional AI models process tokens on remote servers. ALLY D-1 bridges perception and kinetic execution. Powered by our proprietary AgentOS™ spatial stack running on 120 TOPS of local silicon, D-1 translates 3D spatial vision, depth point clouds, and multimodal commands directly into real-time 6-DoF joint trajectories and dynamic gripping postures.
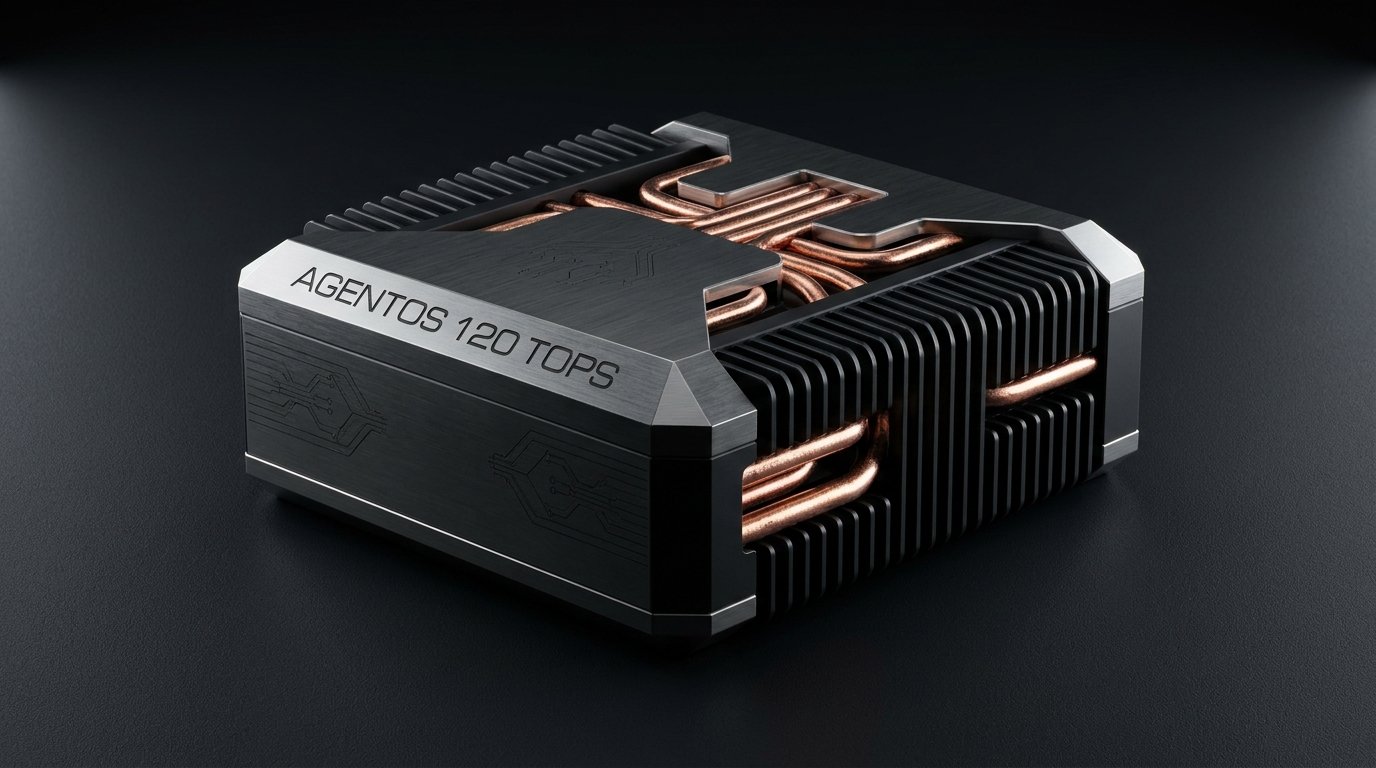
Dual 4K depth cameras map 3D workspace point-clouds in real time, detecting micro-scale components down to 0402 SMD package dimensions.
Direct token-to-trajectory inference on local 120 TOPS silicon. Deconstructs natural instructions into collision-free joint splines without internet.
Aerospace harmonic drive gearboxes paired with multi-axis wrist force-torque sensors deliver sub-Newton tactile sensitivity for delicate tasks.
Bridging digital intent to precision manipulation.
D-1 operates directly alongside your engineering workflow. It coordinates with display outputs, positions micro-electronic components, interfaces with automated test rigs, operates optical inspection probes, and manages laboratory instruments with sub-millimeter precision.
Deterministic inference with zero cloud dependency.
Your workbench is a secure R&D domain. Camera feeds, tactile strain data, and motion trajectories are computed 100% on local NPU silicon. Certified for secure aerospace environments, defense SCIF facilities, and confidential semiconductor labs.
Kinematic Simulation Console.
Test on-device Vision-Language-Action execution in real time. Select an automated benchmark routine or manually jog the 6-axis harmonic joints to verify spatial envelope, closed-loop telemetry, and haptic resistance.
Engineered for Benchtop Precision.
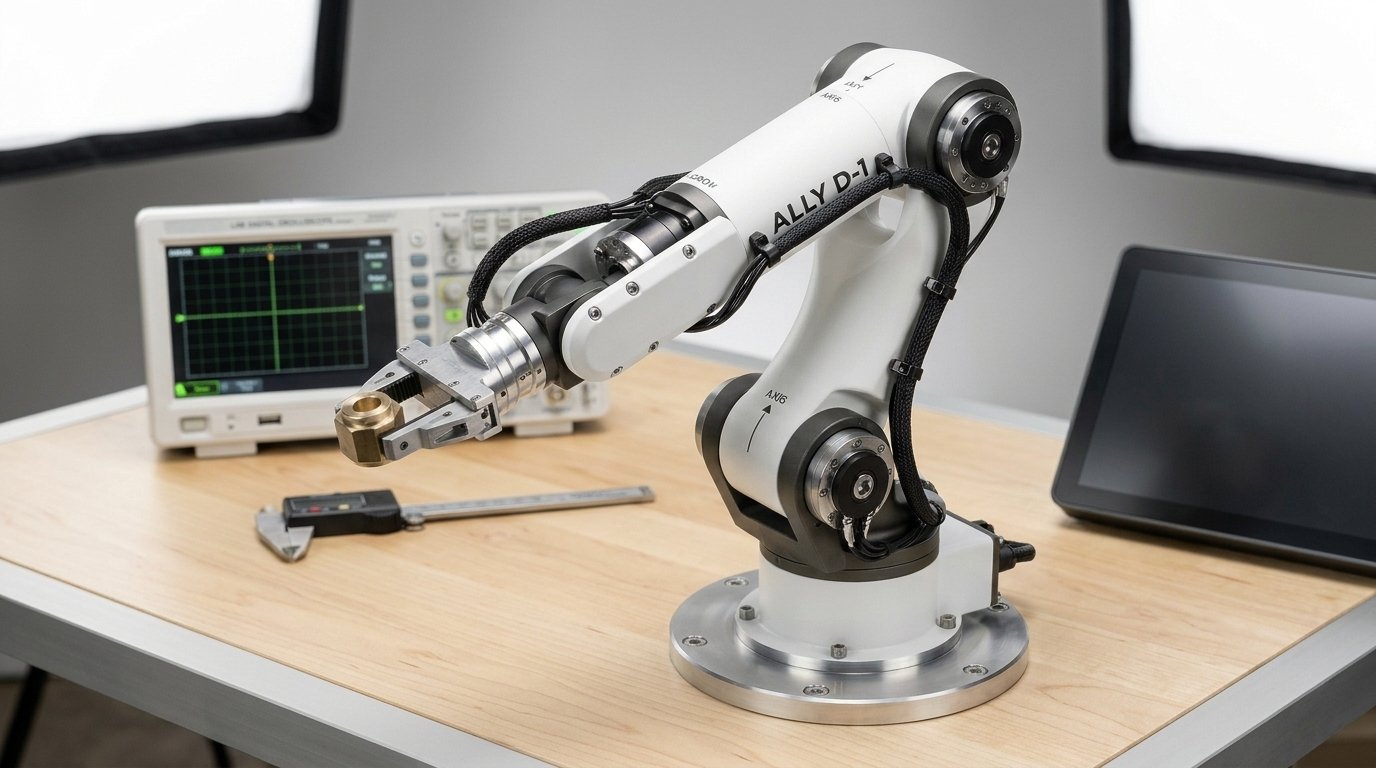
CNC Milled 6061-T6 Alloy
Machined from continuous billets of aircraft-grade aluminum with ceramic powder coat. Zero harmonic resonance even under rapid micro-placement accelerations.
RIGID CHASSISZero-Backlash Strain Wave
Industrial strain-wave gearboxes coupled with 21-bit absolute optical encoders delivering ±0.008 mm repeatability across the entire envelope.
±0.008MM REPEATABILITY520mm Radial Reach
Hemispherical 6-DoF workspace covering your entire workbench. Supports 750g continuous payload with dynamic gravity compensation.
520MM ENVELOPETechnical Specifications & Sensor Suite.
| System Subsystem | Engineering Specification | Operational Performance | Benchmark Standard |
|---|---|---|---|
| Kinematic Articulation | 6-Axis Articulated Arm (Harmonic Drivetrain) | Continuous 6-DoF inverse kinematic trajectory planning | ±0.008mm Repeatability |
| Neural Inference Engine | AgentOS™ Robotics AI Accelerator | 120 TOPS local INT8/FP16 NPU; zero cloud latency | Zero Cloud Dependency |
| Vision & Depth Sensing | Dual Global Shutter Stereo + ToF Sensor | 120 FPS spatial point cloud mapping and sub-mm localization | 0.2mm Spatial Resolution |
| Tactile Force Sensing | 6-Axis Load Cell + Finger Strain Gauges | Sub-Newton force control with active slip detection | 0.02N Sensitivity |
| Spatial Acoustic Array | 4-Channel Beamforming Microphones | Direct spatial voice parsing and acoustic anomaly detection | 98.4% Audio Accuracy |
| Modular Toolchanger | Zero-Play Magnetic Lock + Pogo Interface | Automated end-effector swap in <3 seconds | Universal Mount |
| Hardware Security Enclave | Air-Gapped Cryptographic Co-Processor | Zero telemetry egress; hardware root of trust | SCIF & ITAR Ready |
Modular Industrial End-Effectors.
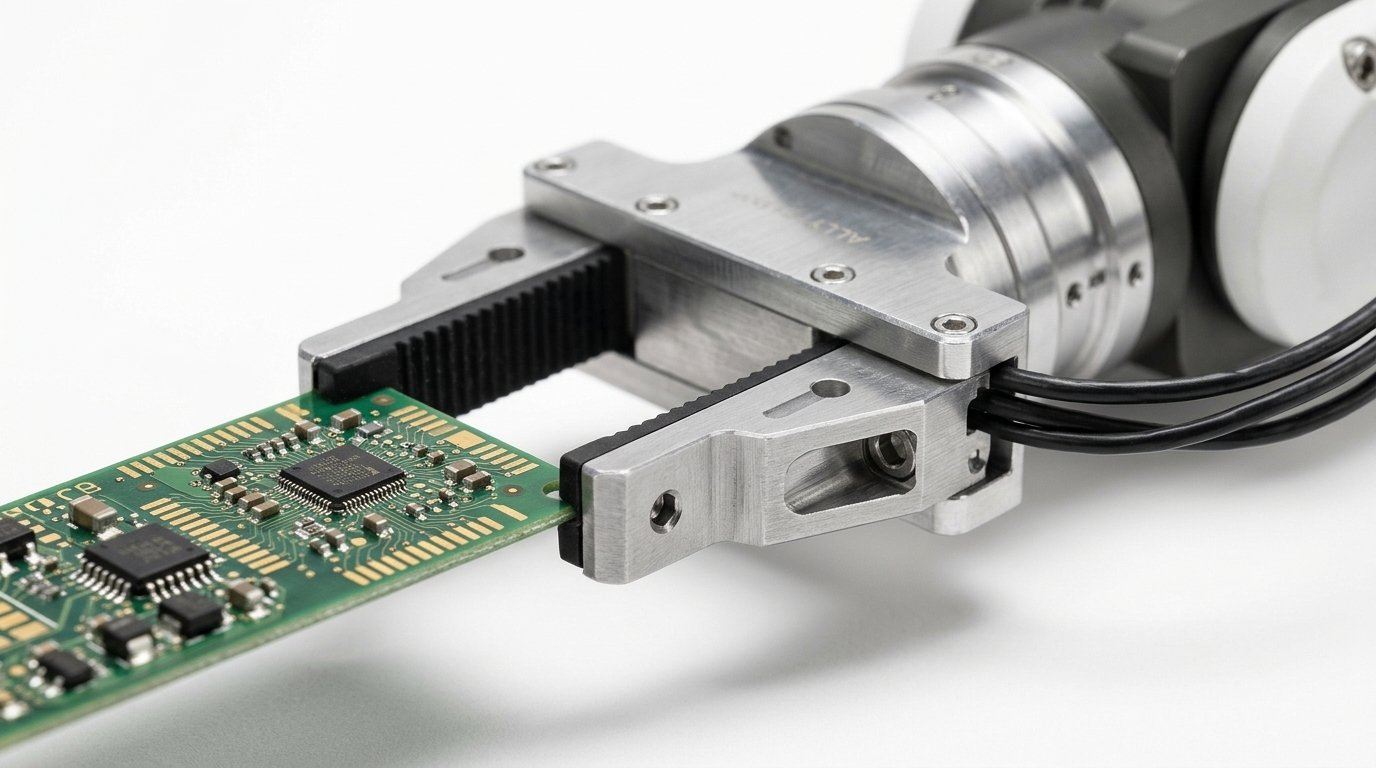
Sub-Millimeter Tactile Control.
From assembling surface-mount microelectronics to handling delicate glassware or cycling automated hardware test keys, ALLY D-1’s end-effectors combine high mechanical stiffness with responsive micro-force sensitivity.
Parallel Electric Gripper
Dual-finger parallel mechanism with interchangeable silicone pads and integrated strain sensors. Securely grips fragile chips, wires, and tools.
TACTILE FEEDBACKMicro-Dispenser Scribe
Pneumatic syringe toolhead for precise deposition of conductive inks, solder paste, UV adhesives, or liquid reagents down to 0.01 μL.
0.01μL FLUID CONTROLMacro Optical Probe
4K high-magnification coaxial inspection camera with polarized ring lighting for PCB solder bridge inspection and surface crack analysis.
4K MICROSCOPIC VISIONHigh-Speed Vacuum Pick Head
Venturi vacuum suction nozzle with anti-static silicone cups for ultra-fast picking and sorting of SMD silicon dies and delicate wafers.
VACUUM RETRIEVALReserve Your ALLY D-1 Allocation.
Batch 01 production is strictly limited to 500 numbered units for advanced robotics teams, aerospace engineers, and laboratory researchers. Includes core parallel gripper, AgentOS™ SDK, and calibrated sensor suite.